


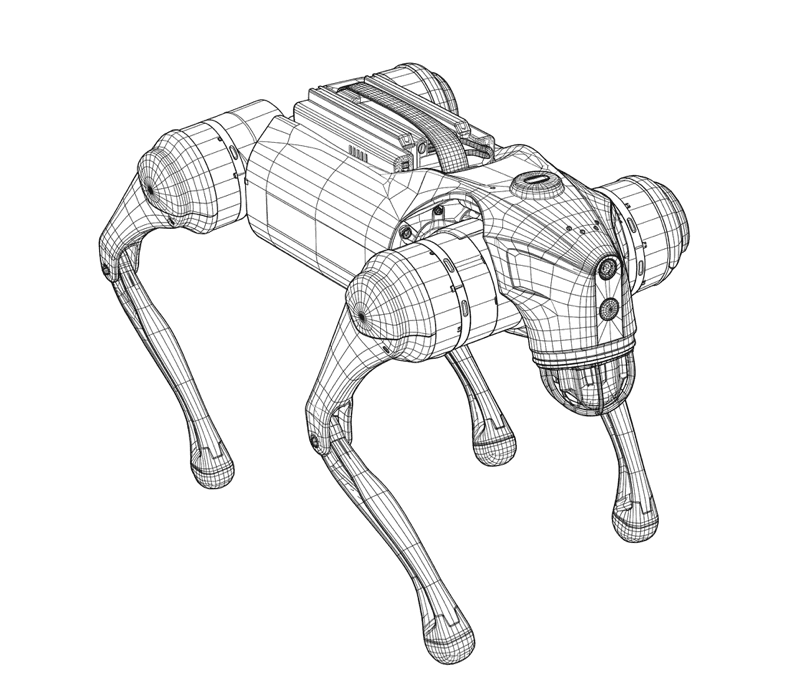
Rehearse
Your robot runs the job in physics long before it runs it on hardware.
Your robot runs the job in physics long before it runs it on hardware.
Every pass hands back labelled trajectories. Nothing collected by hand.
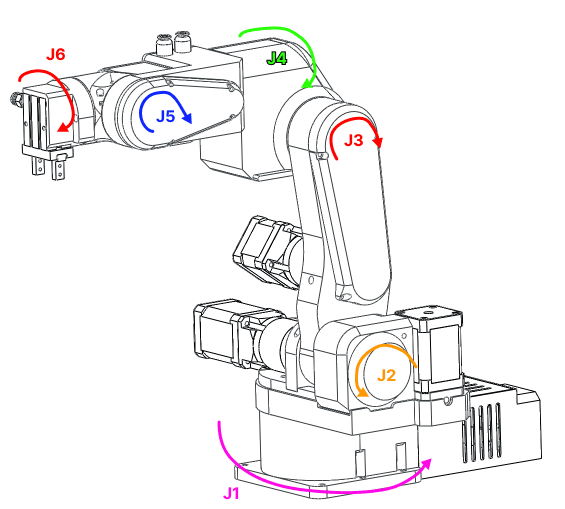
Each checkpoint measured against the last, with the numbers behind it.
URDF, the scene, your checkpoint.
4,096 passes, varied every time.
Trained on what came back.
Artifacts out. Our copy deleted.
Screened bar is discarded when the run closes.
50.4 GB delivered
We are taking on a small number of robots at a time. Tell us what yours has to do.